Leona (Nhi) Nguyen
Greetings, I am a MS Robotics student at Georgia Tech, where I do household robot learning research under Prof. Sonia Chernova in the RAIL lab and dexterous manipulation under Prof. Animesh Garg in the PAIR lab.
My research interests lies in curiosity-driven reinforcement learning, interactive robot learning, semantic mapping, and dexterous manipulation. I aim to apply these methods to assistive and household robots that must learn in dynamic, human-centric environments.
Previously, I completed my BS in Robotics Engineering and Computer Science at Worcester Polytechnic Institute (WPI), where I worked with Prof. Carlo Pinciroli on swarm robotics and multi-agent communication at Nest lab.
CoRL 2025 Workshop Dexterous Manipulation Spotlight
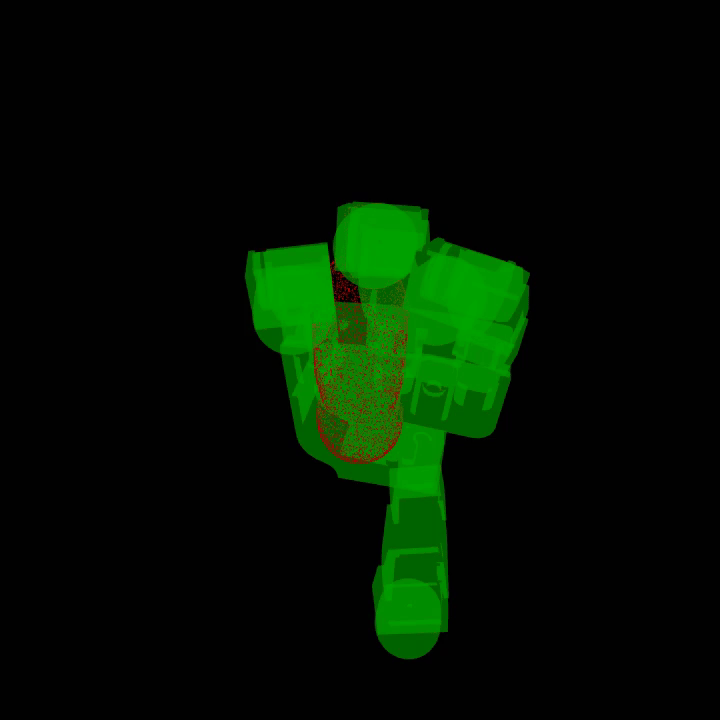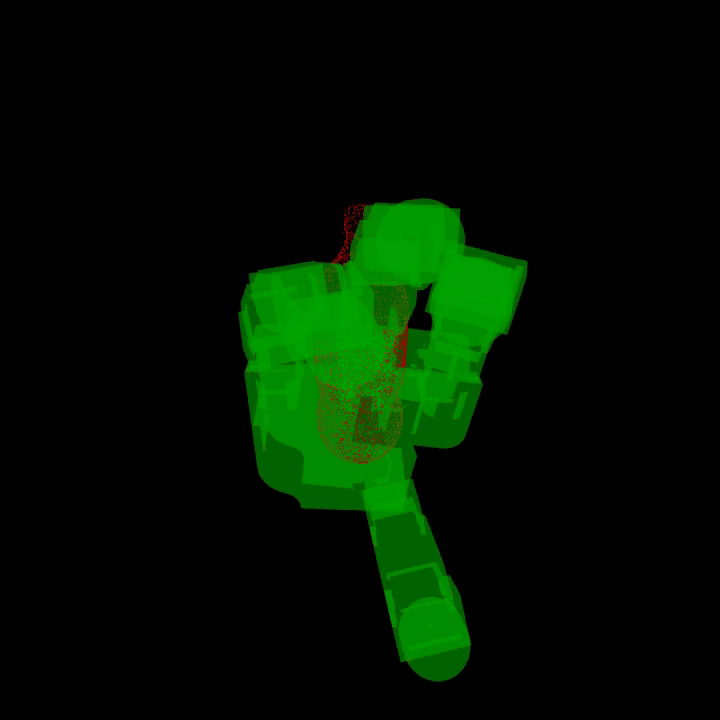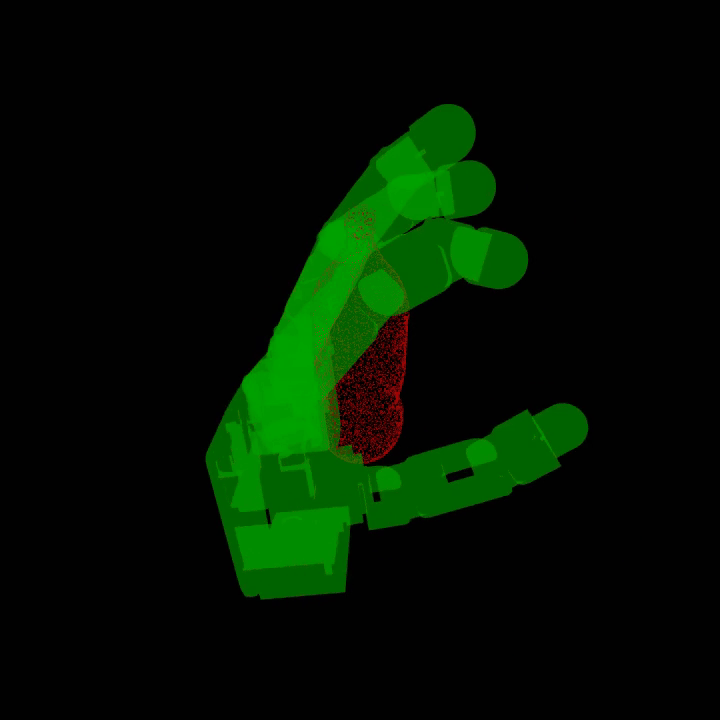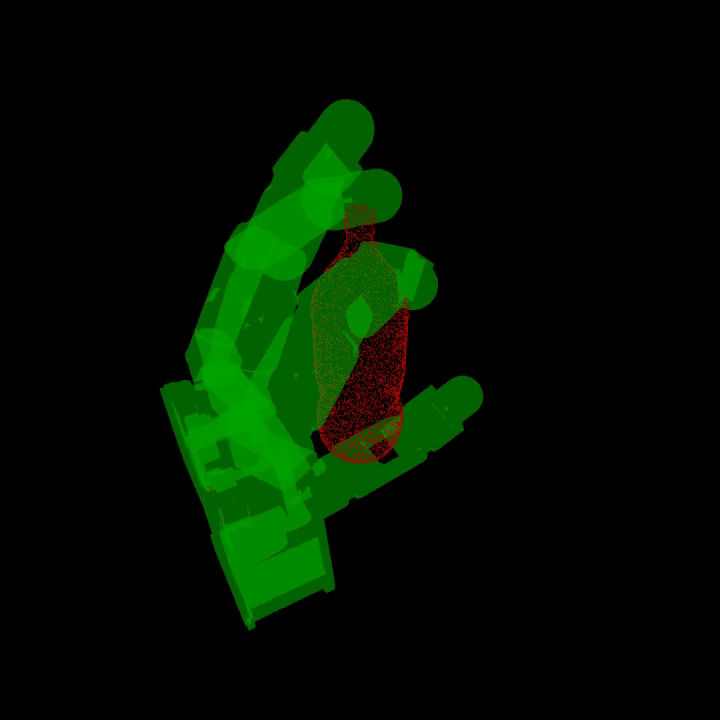
Dexterous Manipulation Flow Models
A method for language-conditioned dexterous grasping that jointly models task intent and physical contact quality for robot hands.
Hello-Robot Newsletter, April 2025
Semantic Mapping Dynamic Environments
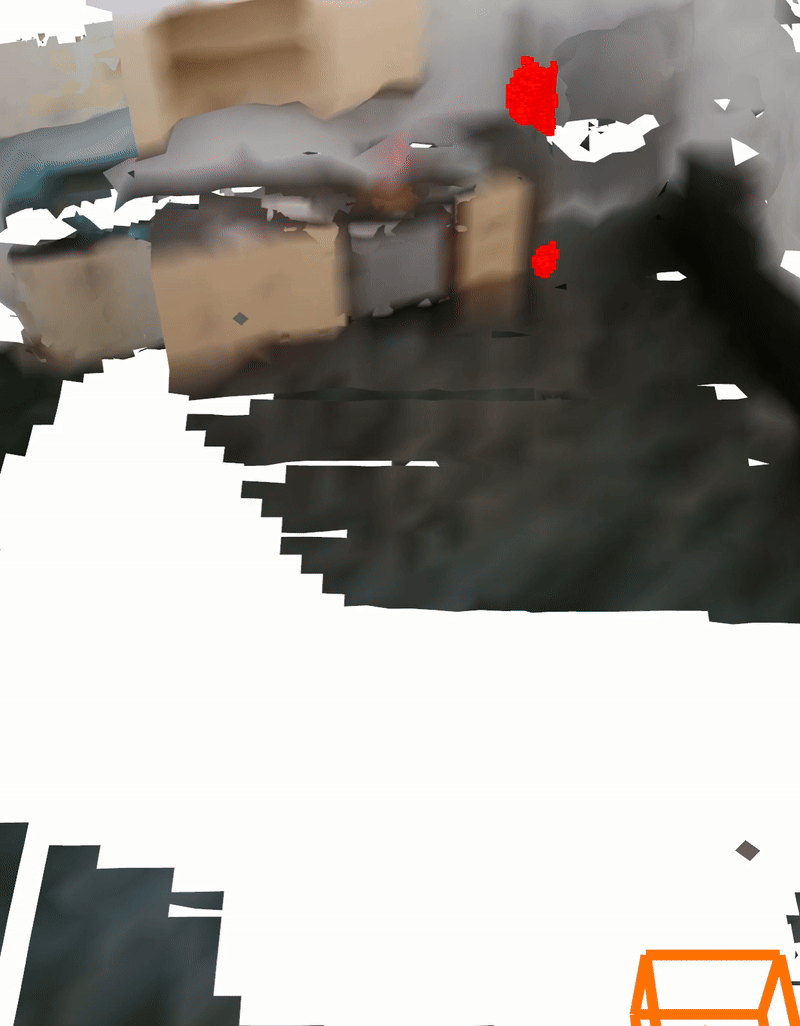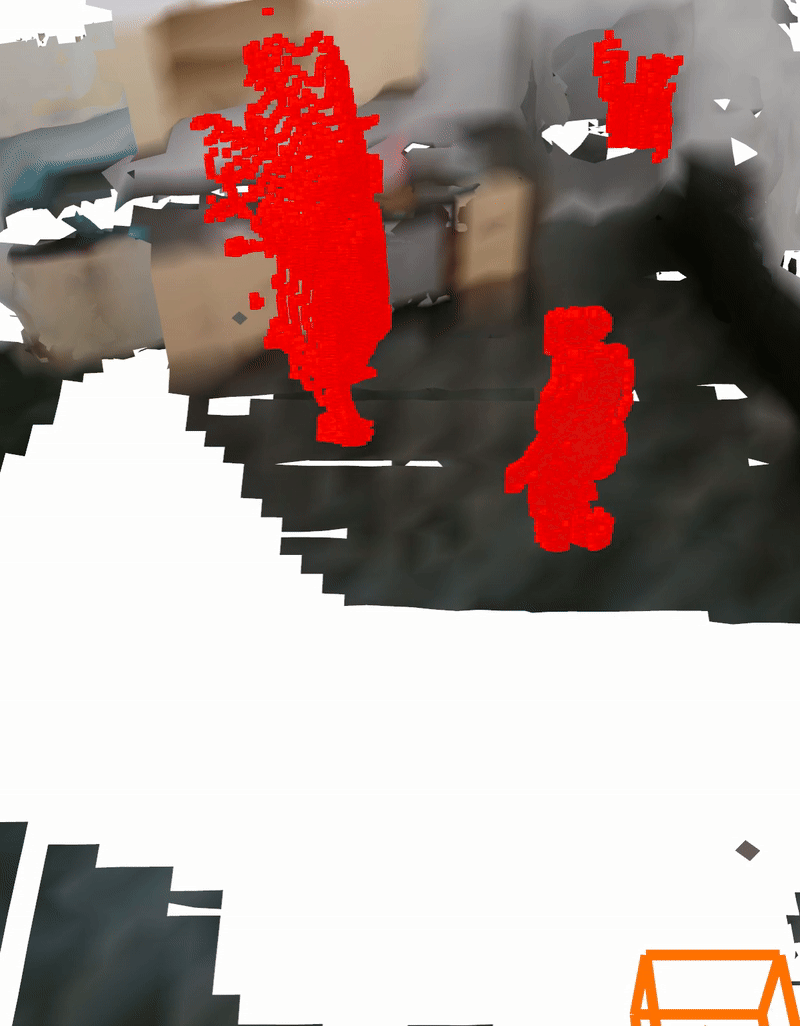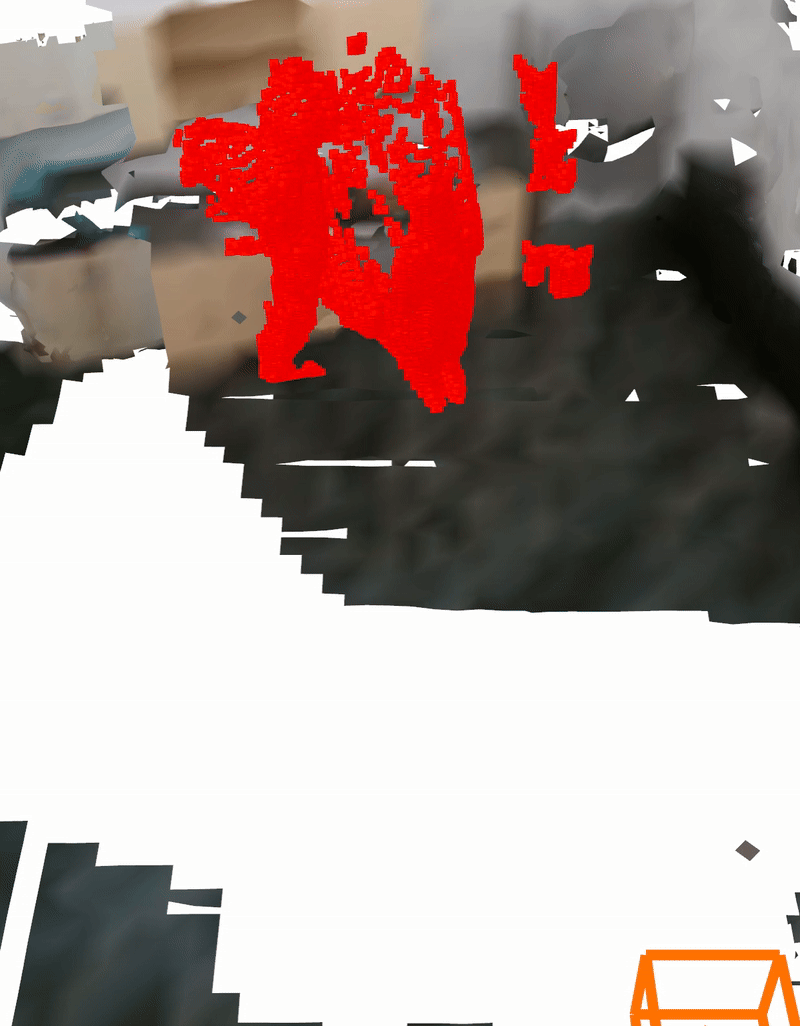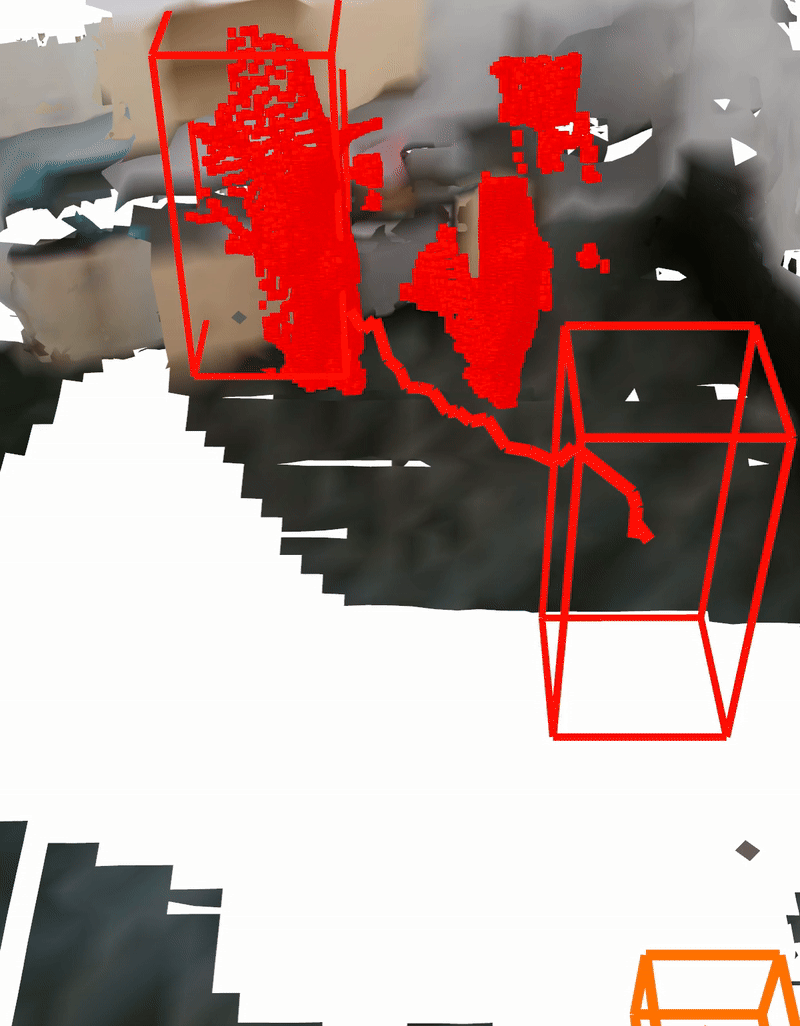
An open-source system for mobile manipulators that builds and updates semantic maps of large, dynamic environments. By integrating ORB-SLAM2, semantic segmentation, and the Khronos mapping pipeline, it tracks moving objects and people over time, enabling long-term scene understanding.
In review journal, Advanced Robotics Research
Survey Dexterous Manipulation Reinforcement Learning
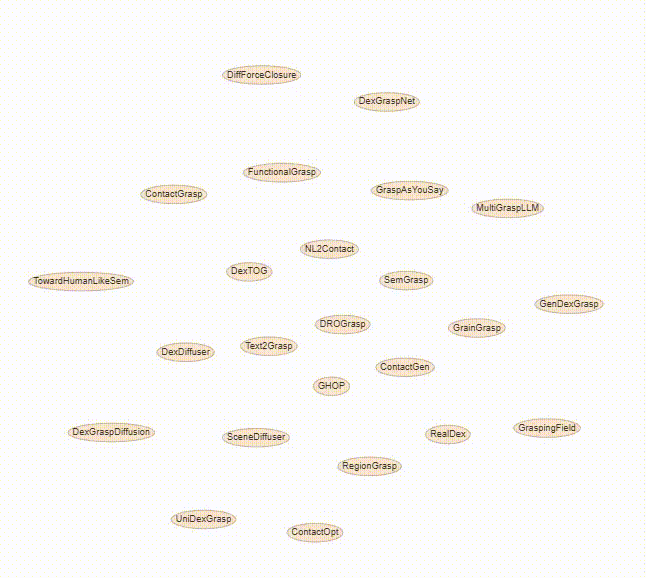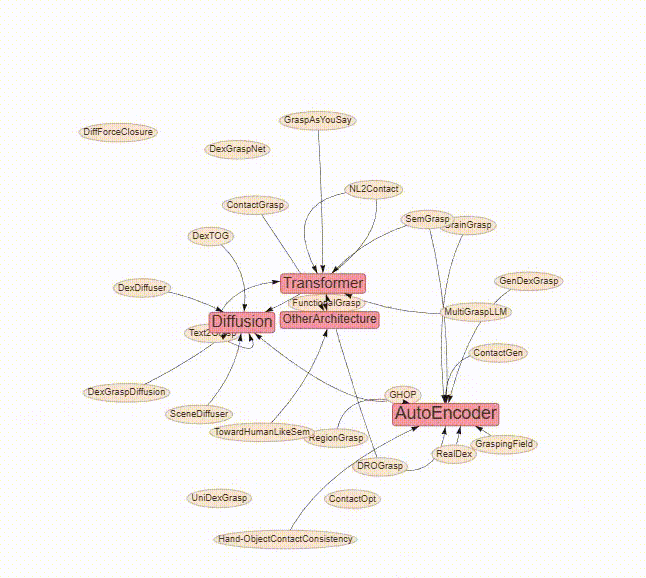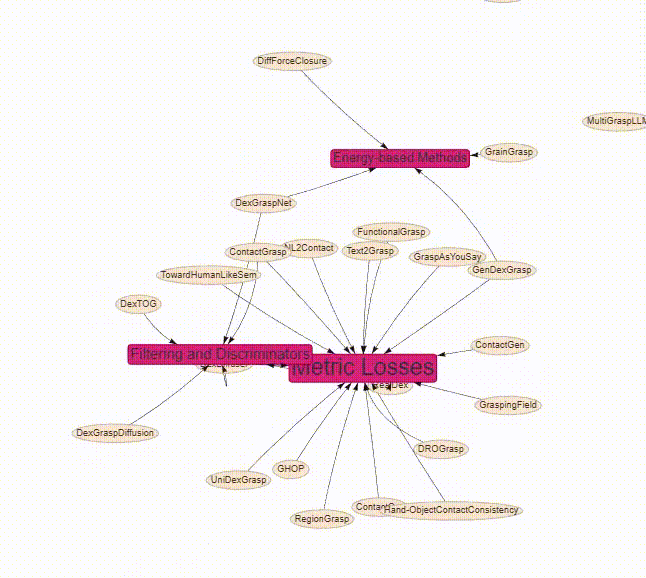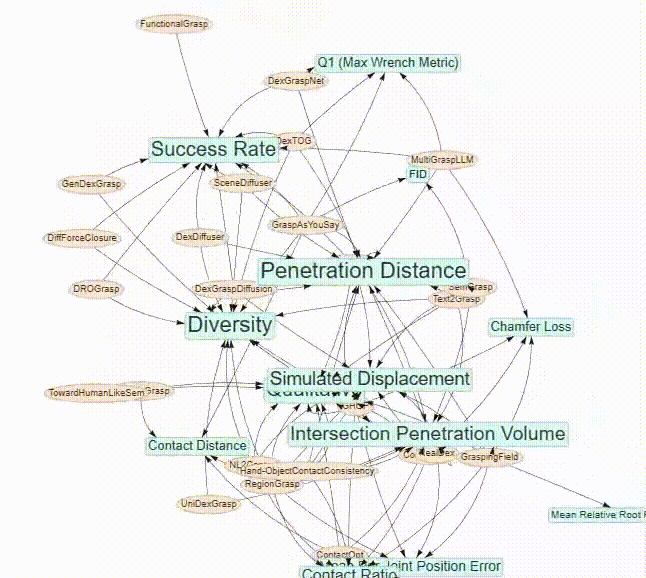
A comprehensive survey of deep learning approaches for dexterous robotic grasping, emphasizing recent progress enabled by multi-modal models and data-driven techniques.
ACM CCS 2024, Co first author
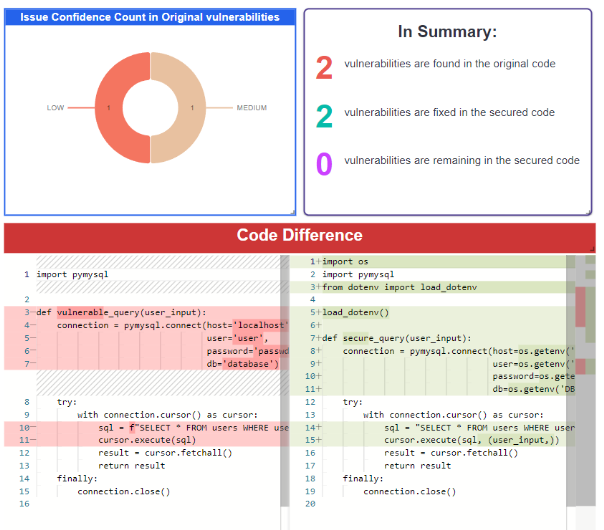
LLMs Internship Security
A flexible prompt-optimizing system for generating secure code with LLMs. SGCode integrates prompt-optimization approaches with security tools and a lightweight generative adversarial graph neural network to detect and fix vulnerabilities in generated code.
Manipulation Reinforcement Learning
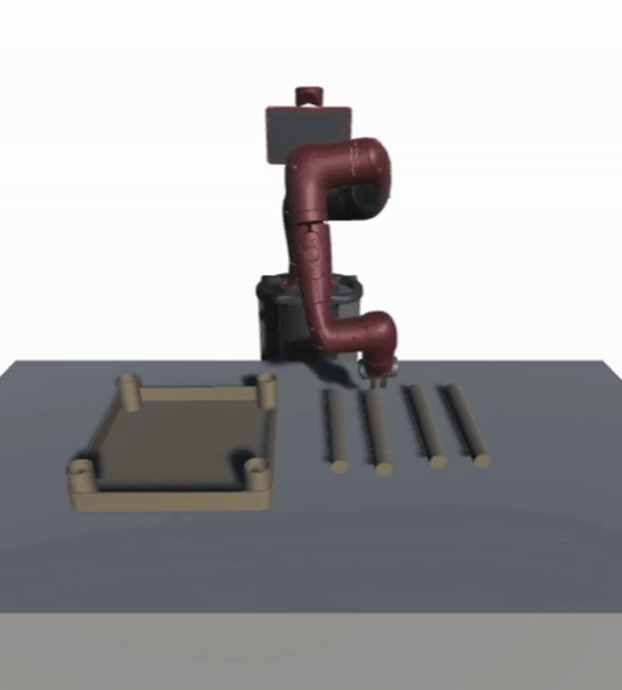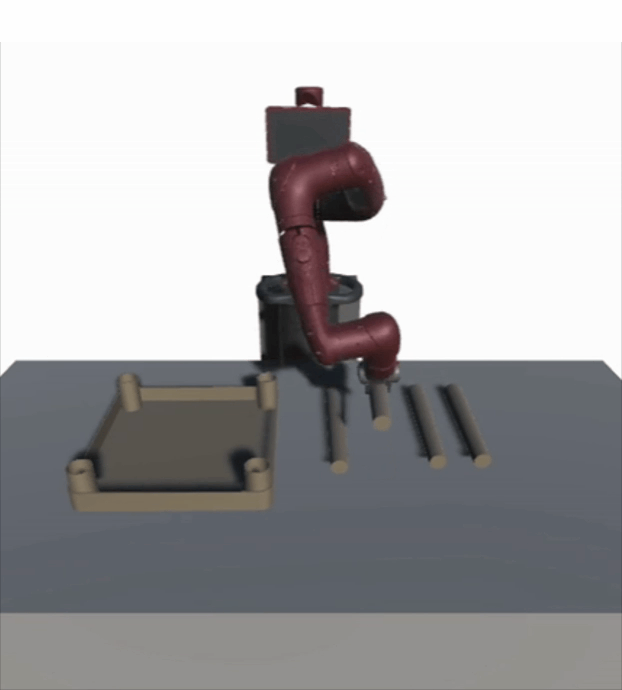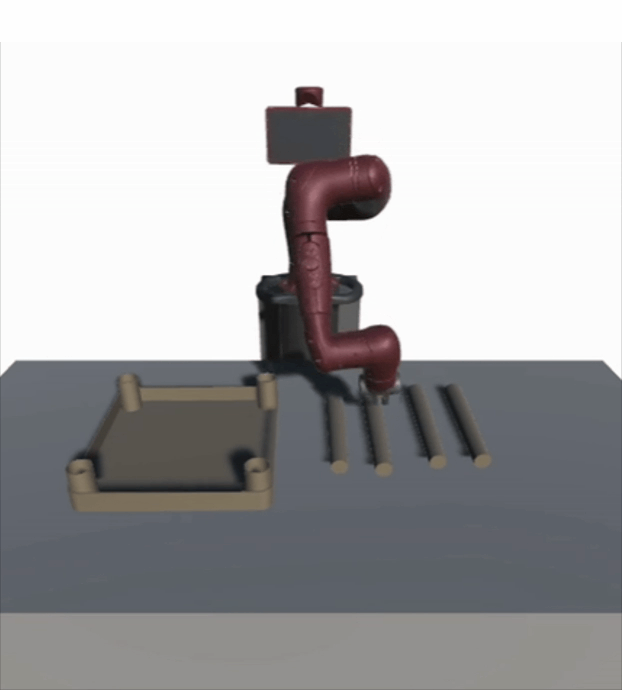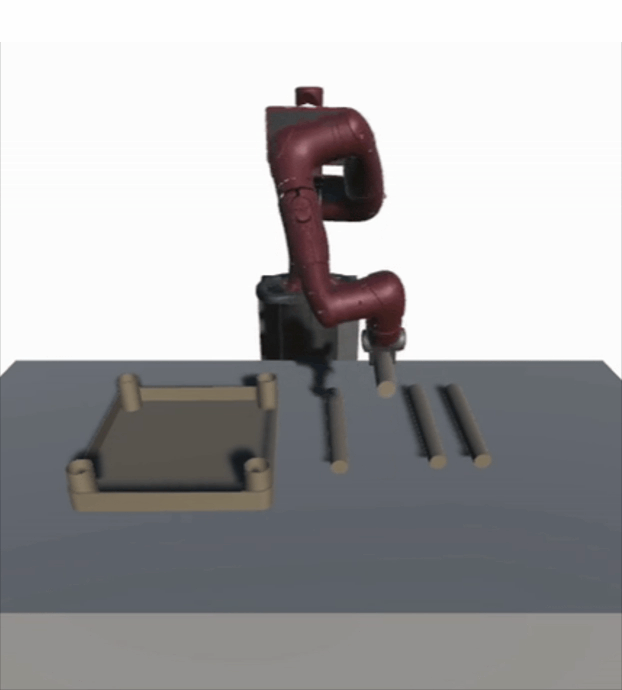
A hierarchy RL policy that enables robots to actively seek human guidance through hints rather than full demonstrations to recover from mistakes before total failure. I proposed the idea and implemented the framework in Robosuite. I will revisit this at some point.
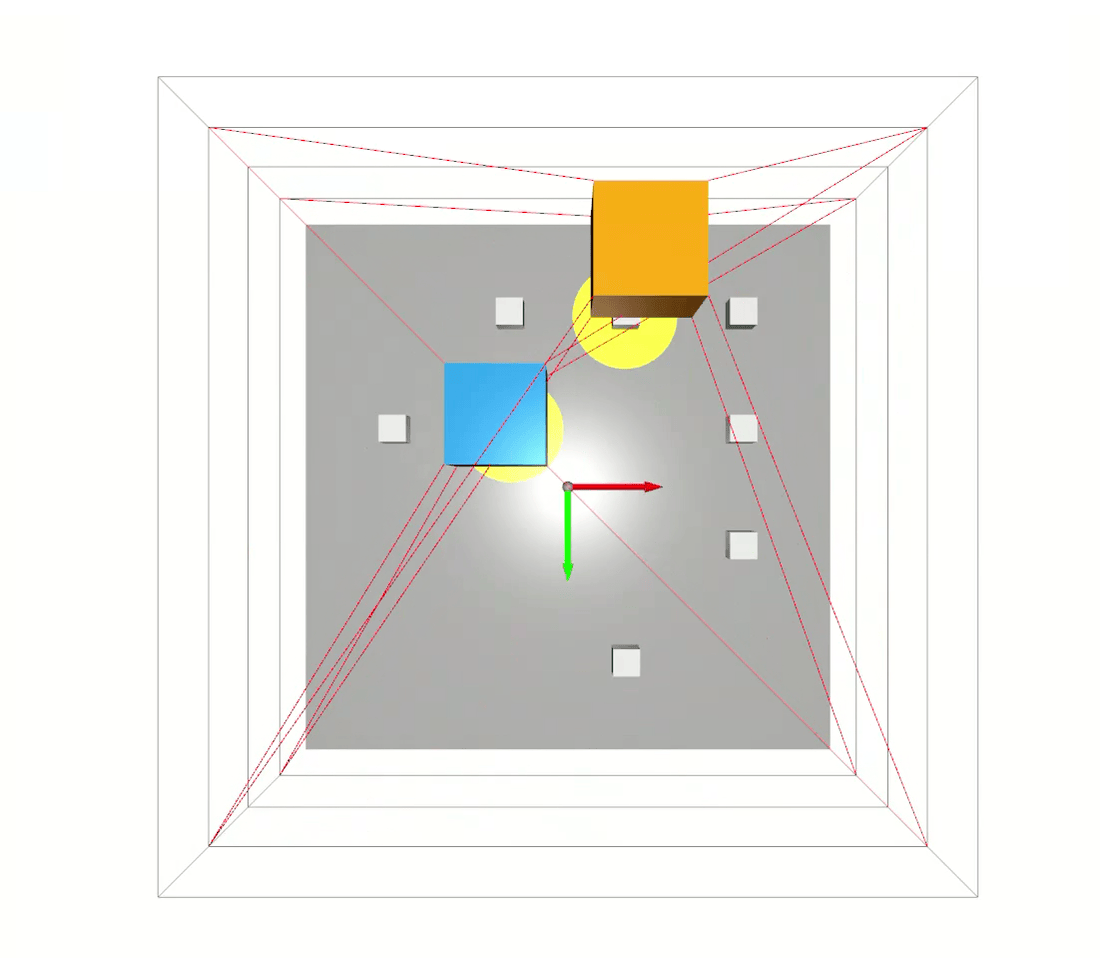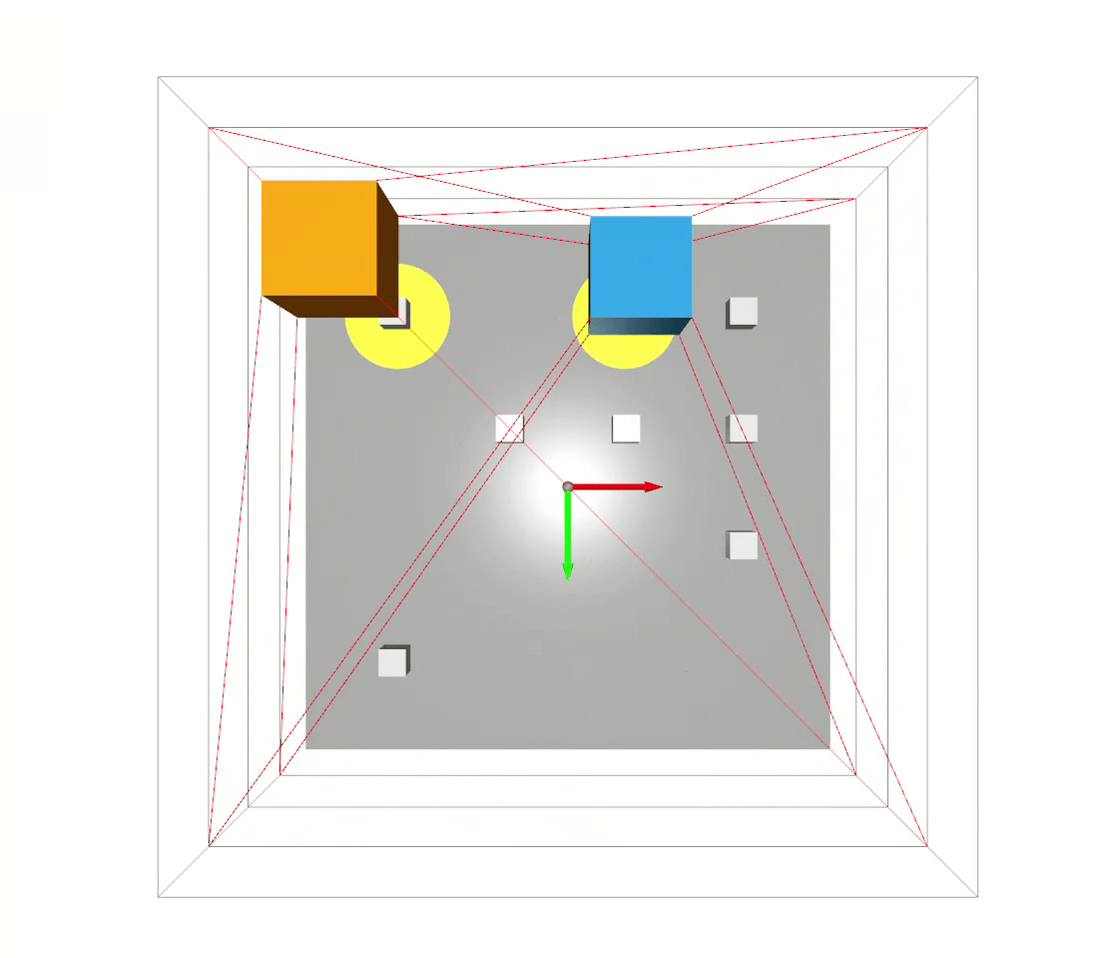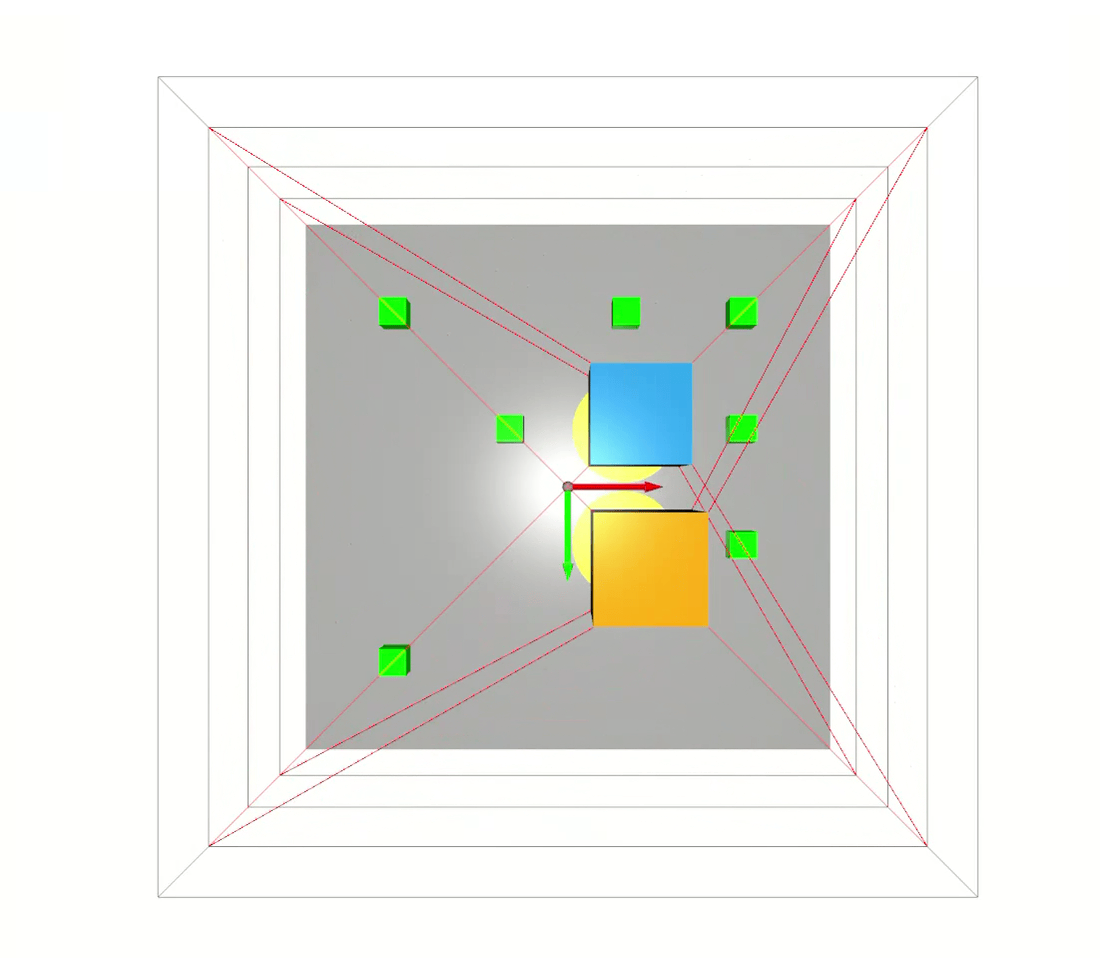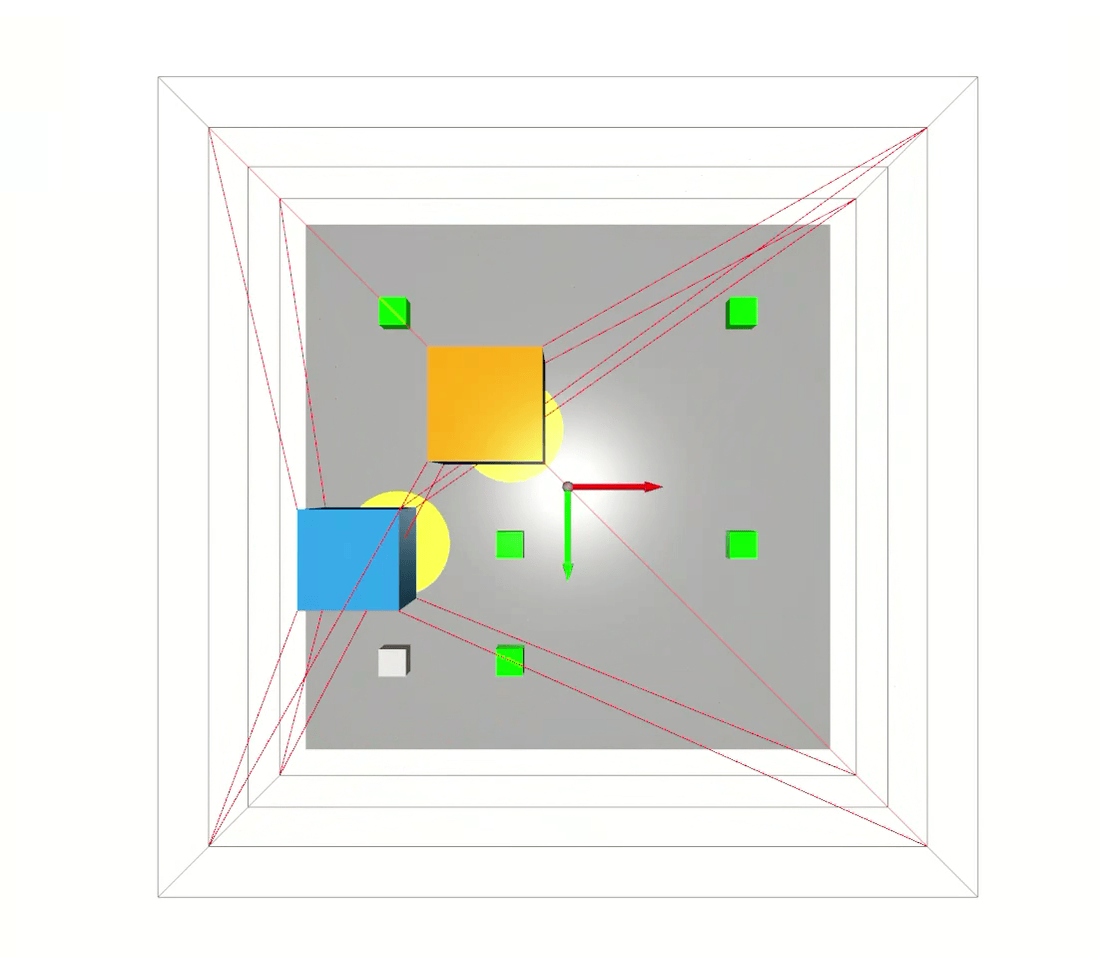
Reinforcement Learning Multi-Agents
Reinforcement learning implementations for cable-driven parallel robots designed for agricultural monitoring and inspection tasks.
Multi-Agents Wireless Communications
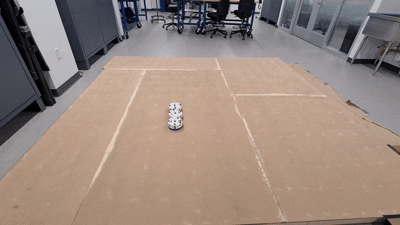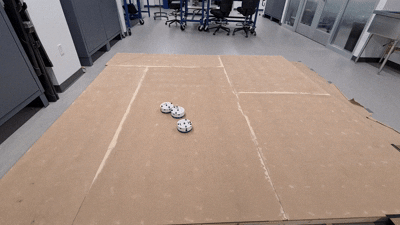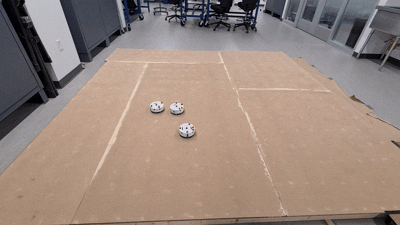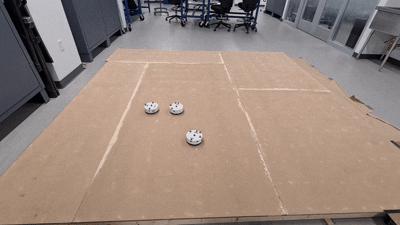
Proposing and implementing a range and bearing communication method that allows robots to use real-life and simulation sensors in a simulated environmen for the ARGoS3 open-source multi-agent simulations. It was my first time using the Vicon motion capture system!
Manipulation Computer Vision
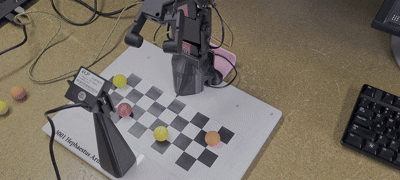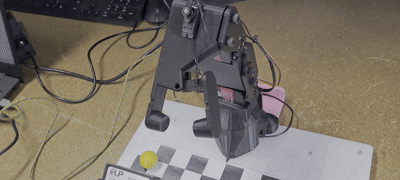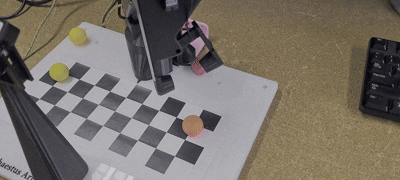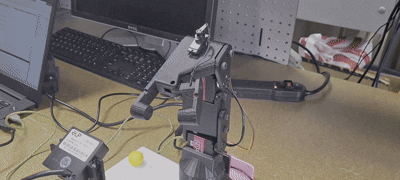
Built a vision-guided manipulation system that detects colored balls, localizes them in 3D, and performs reliable pick-and-place sorting using forward/inverse kinematics and motion control.
Wireless Communications Built Robots Computer Vision
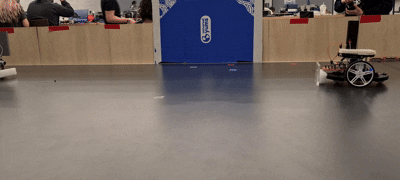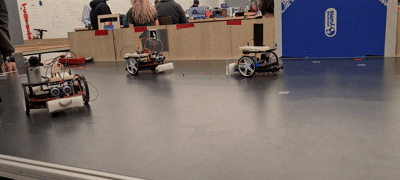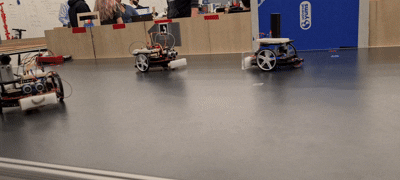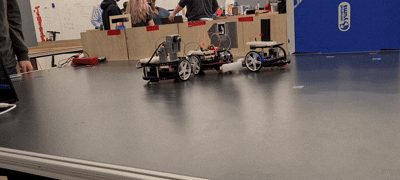
An autonomous multi-robot reenactment of Romeo and Juliet, using MQTT communication, IMU collision detection, ultrasonic sensing, ICC kinematics, and AprilTag tracking to coordinate scene-based behaviors.
SLAM Mapping ROS2
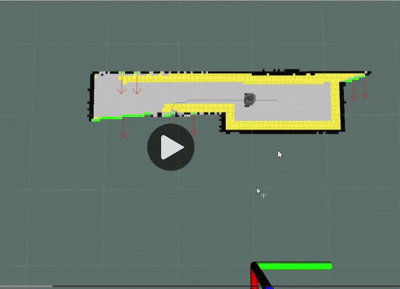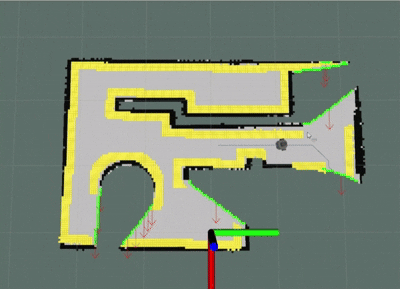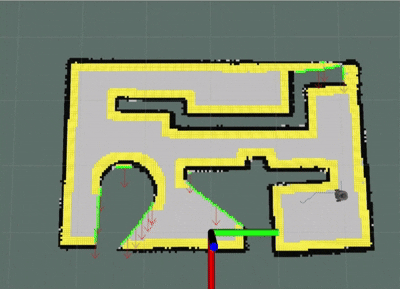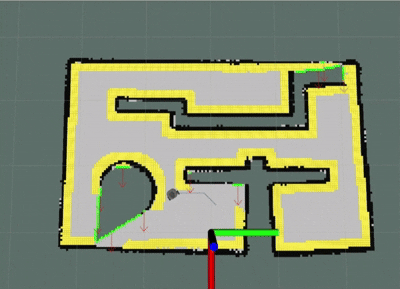
Deployed a TurtleBot3 in an unknown maze environment, utilizing particle filter localization and A* path planning while continuously updating its uncertainty model to enable robust autonomous navigation-validated both in simulation and real-world scenarios.
Apart from robotics, I also like to do digital arts, play with electronics, a LEGO enthusiast and trying to get higher rank in Kendo! See more →